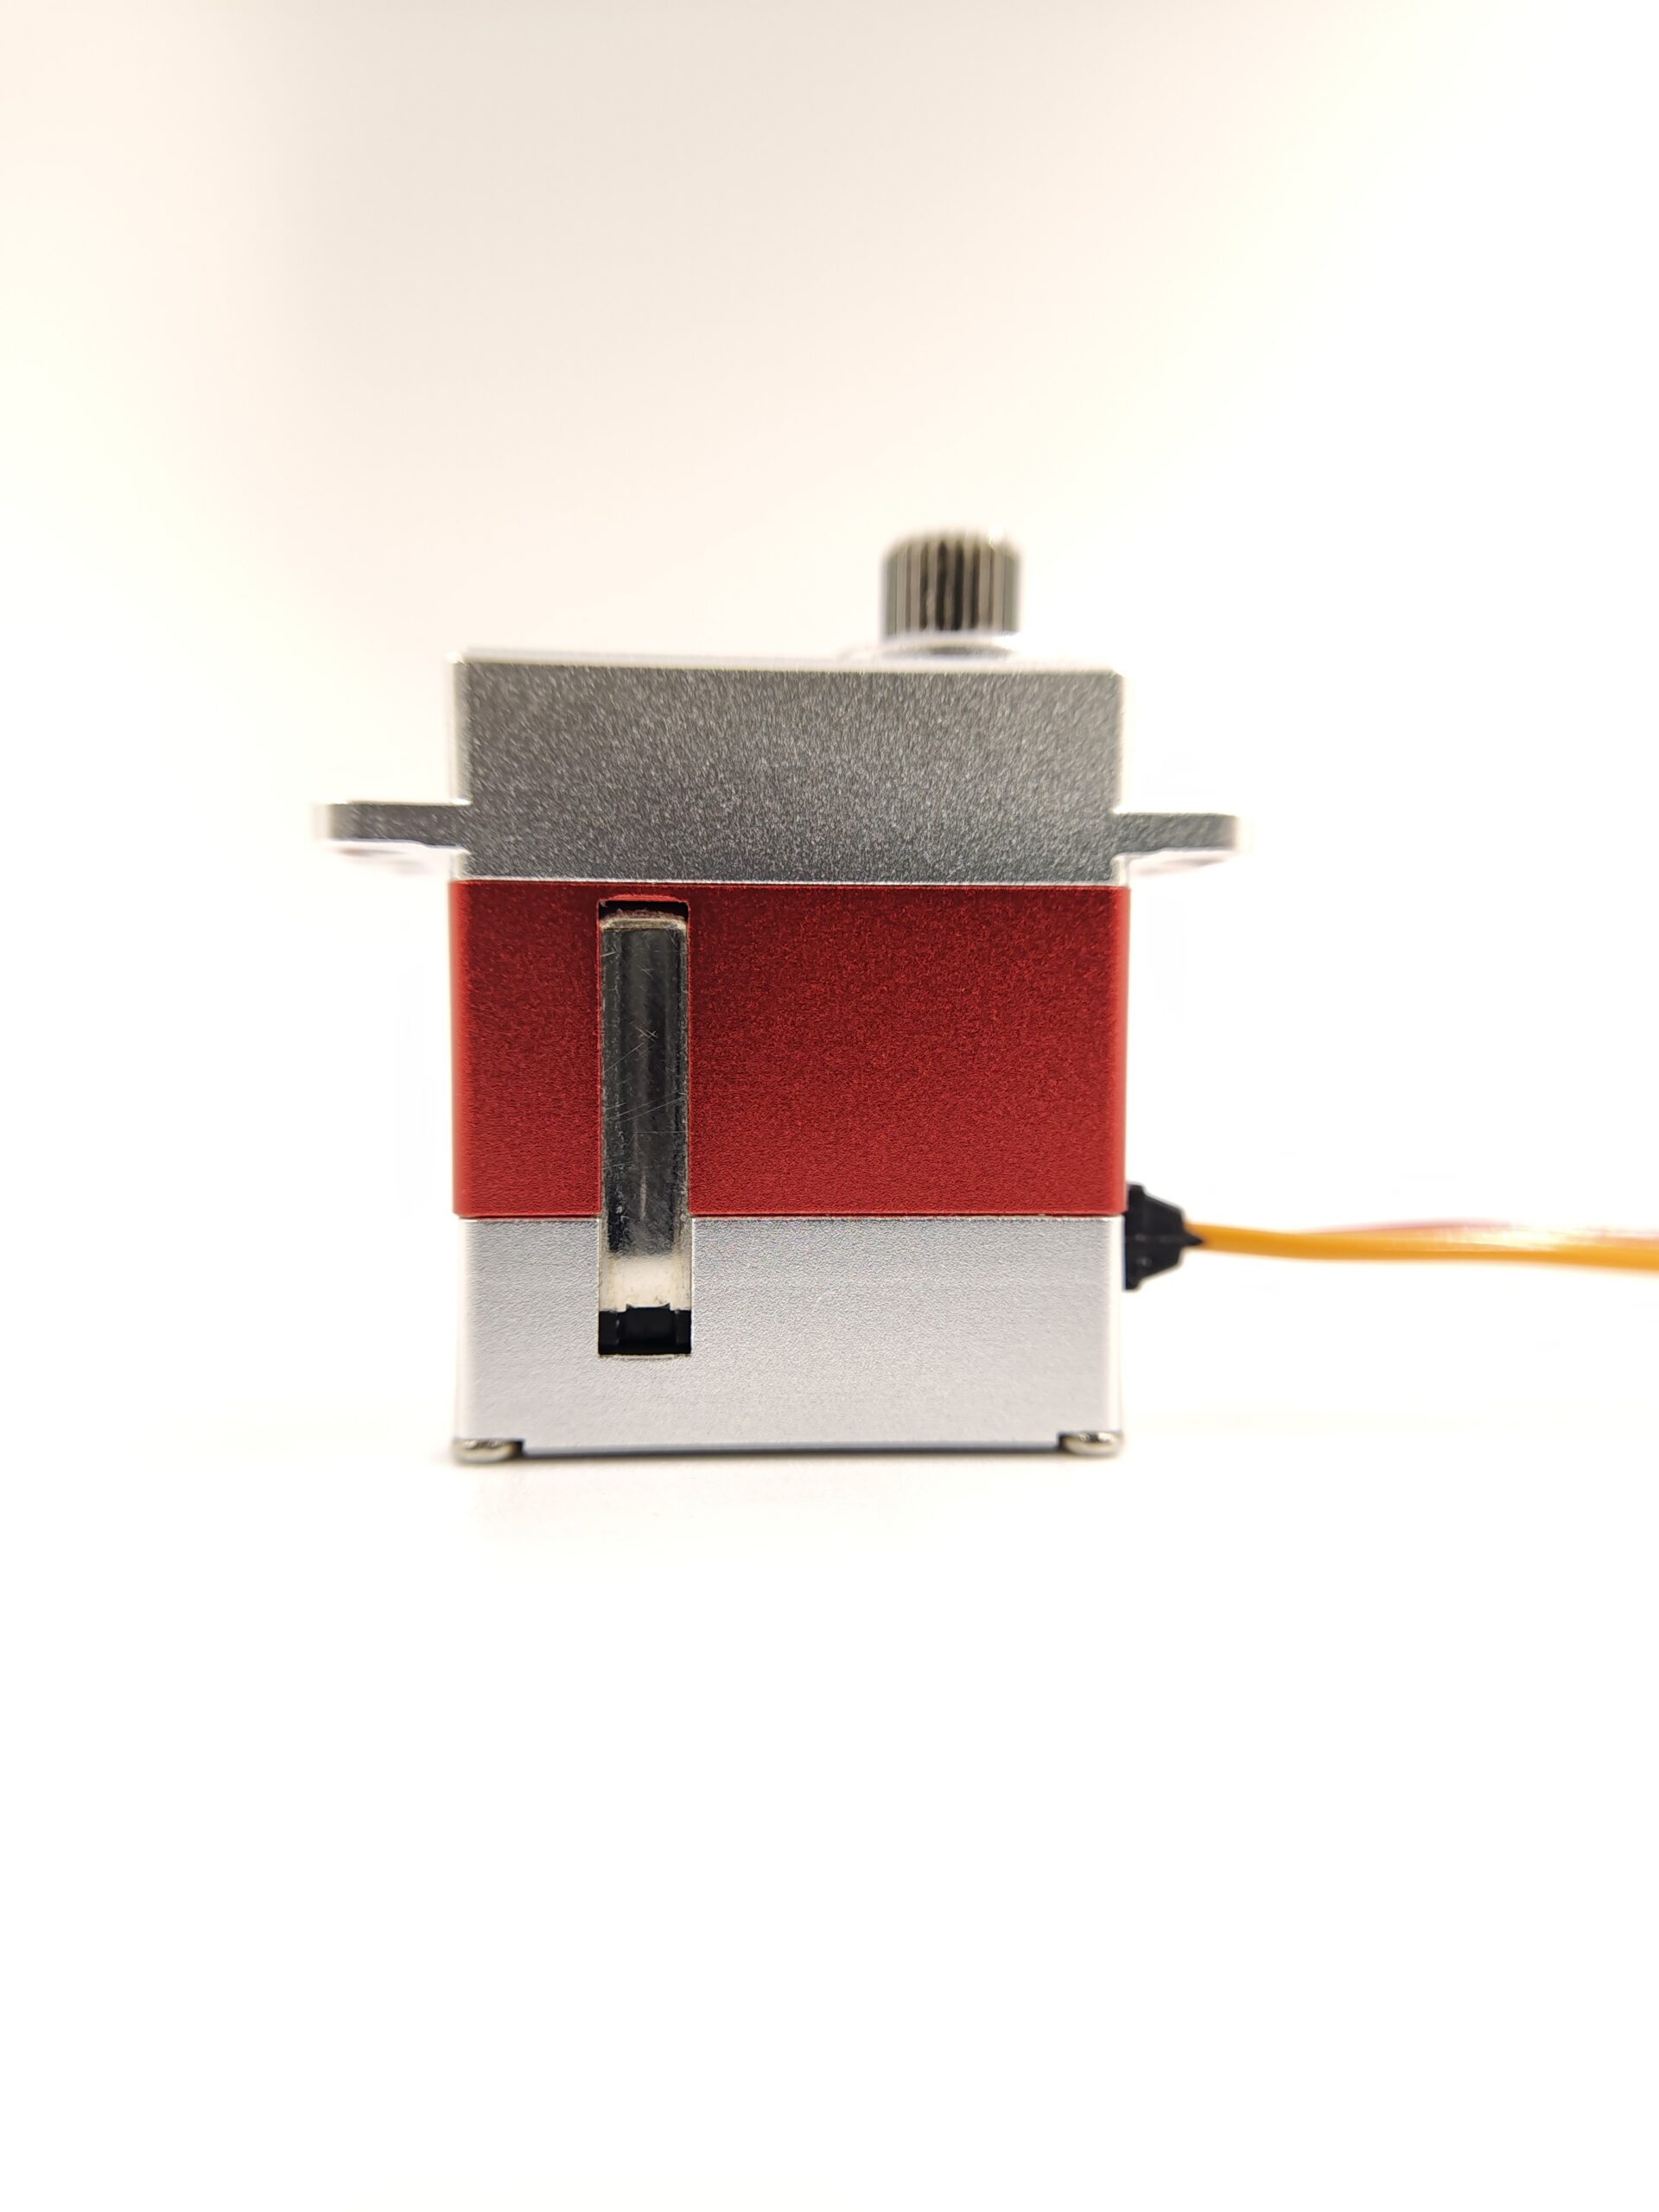
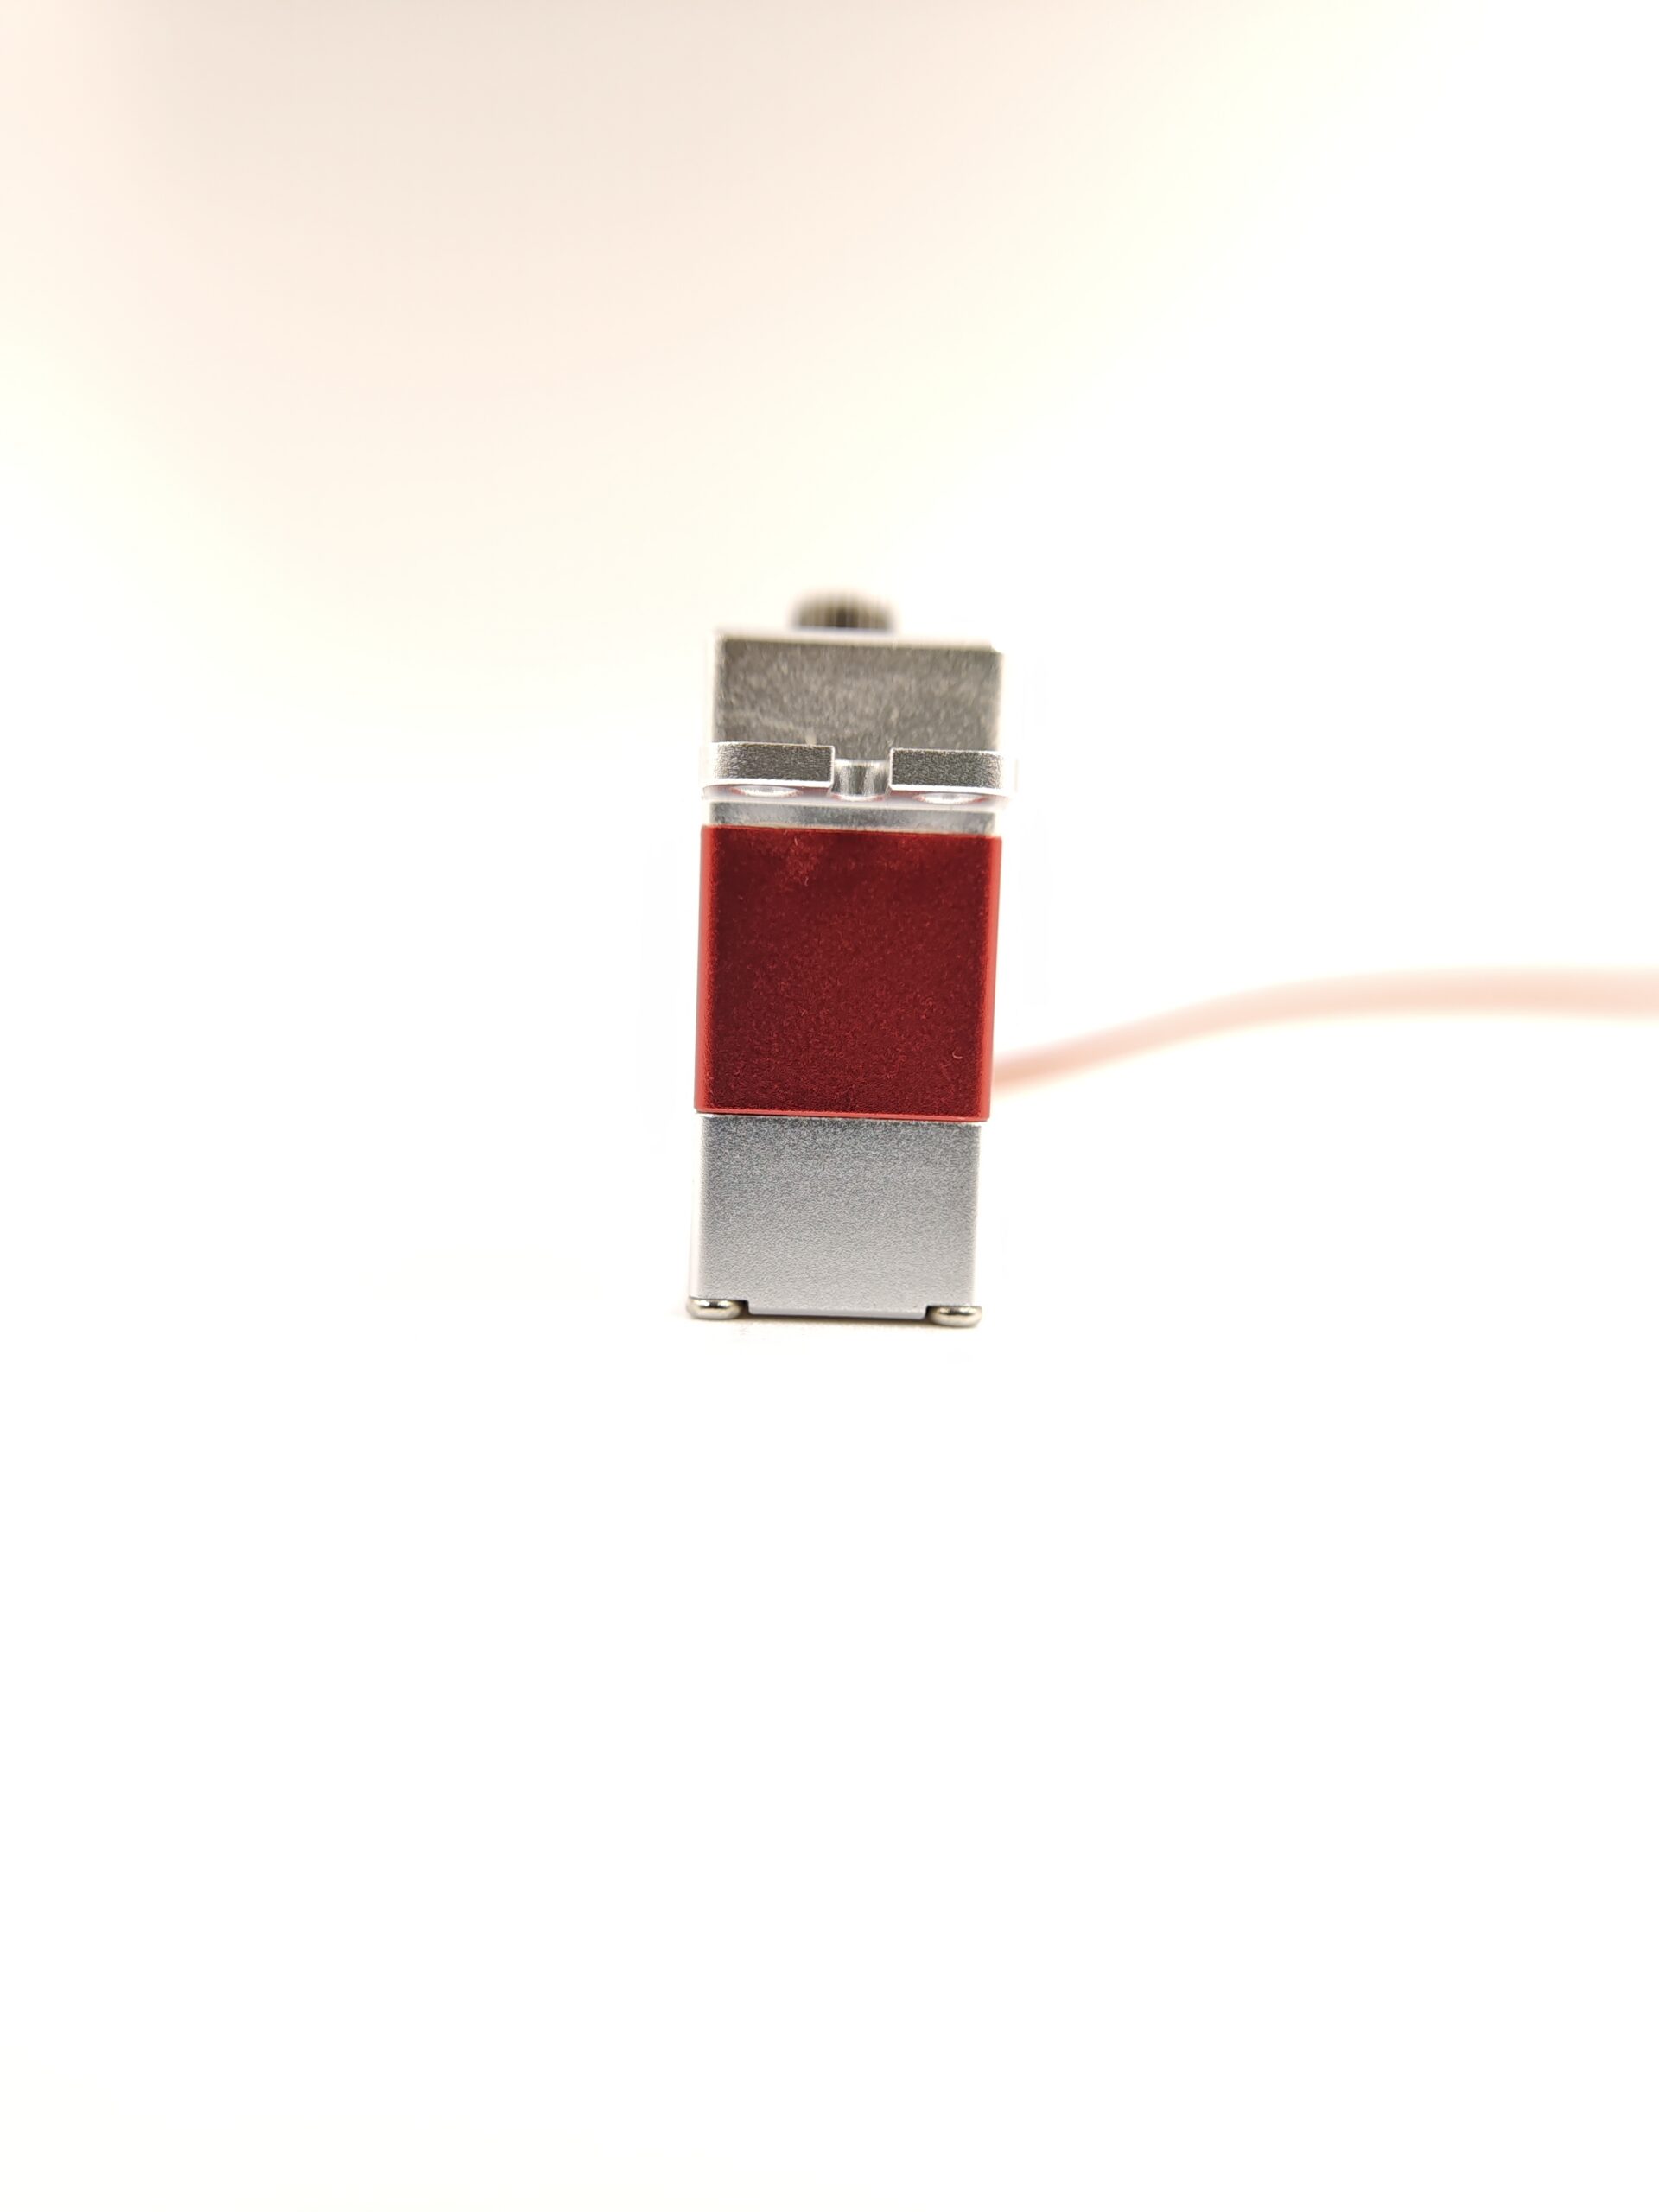
C12204-001 Mini All-Metal Coreless Servo (PWM)
¥150.00 CNY
High-life coreless motor · PWM signal · compact size · high torque · precision metal gears
Samples from 1 piece · OEM / ODM welcome · Datasheet sent with the quote
The C12204-001 packs a coreless brushed motor and a full metal gear train into a
23 x 12 x 27.5 mm housing. At 8.4 V it delivers 5.3 kg·cm while holding
0.07 s/60° — a power density that suits tight installations where a standard
micro servo runs out of headroom.
This PWM variant is driven by a standard RC pulse (1000-2000 us at 50 Hz), so it
drops straight into any receiver or flight controller without extra firmware work.
Typical uses: control surfaces on fixed-wing models and helicopter linkages,
steering on RC cars, joints on desktop robots and small quadrupeds, finger joints
in dexterous hands, pan/tilt on compact camera gimbals, and robotics teaching kits.
Features
- Coreless brushed motor — no iron core in the rotor, so inertia stays low
and start/stop response is quick. Service life is well beyond a comparable
cored motor. - Compact envelope, high output — 23 x 12 x 27.5 mm, 21 g, up to 5.3 kg·cm.
- Full metal gear train and case — machined metal gears resist wear; the
metal shell helps dissipate heat and adds rigidity under shock loads. - Tight backlash — precision-cut gears keep positioning repeatable over a
long service life. - Wide input range — 3.6 V to 10 V, so a 1S or 2S LiPo can drive it directly.
Specifications
| Control interface | PWM (1000-2000 us, 50 Hz) |
|---|---|
| Voltage range | 3.6-10V |
| Dimensions | 23 x 12 x 27.5 mm |
| Weight | 21 g |
| Output shaft | Spline |
| Motor type | Coreless brushed |
| Gear material | Full metal |
| Case material | Full metal |
| Torque | 3.0 kg.cm@4.8V, 3.8 kg.cm@6.0V, 4.7 kg.cm@7.4V, 5.3 kg.cm@8.4V |
| Speed | 0.105 s/60°@4.8V, 0.095 s/60°@6.0V, 0.08 s/60°@7.4V, 0.07 s/60°@8.4V |
Package Including
- C12204-001 servo x 1
Documentation
- C12204-001 technical page — specifications, performance by voltage and integration notes
- PWM control — pulse width, frame rate and wiring
- UART Bus Protocol (PDF) — packet format, instruction set, and error handling for the serial bus variants
- Control Table Example (PDF) — register map with addresses, access rights, and default values